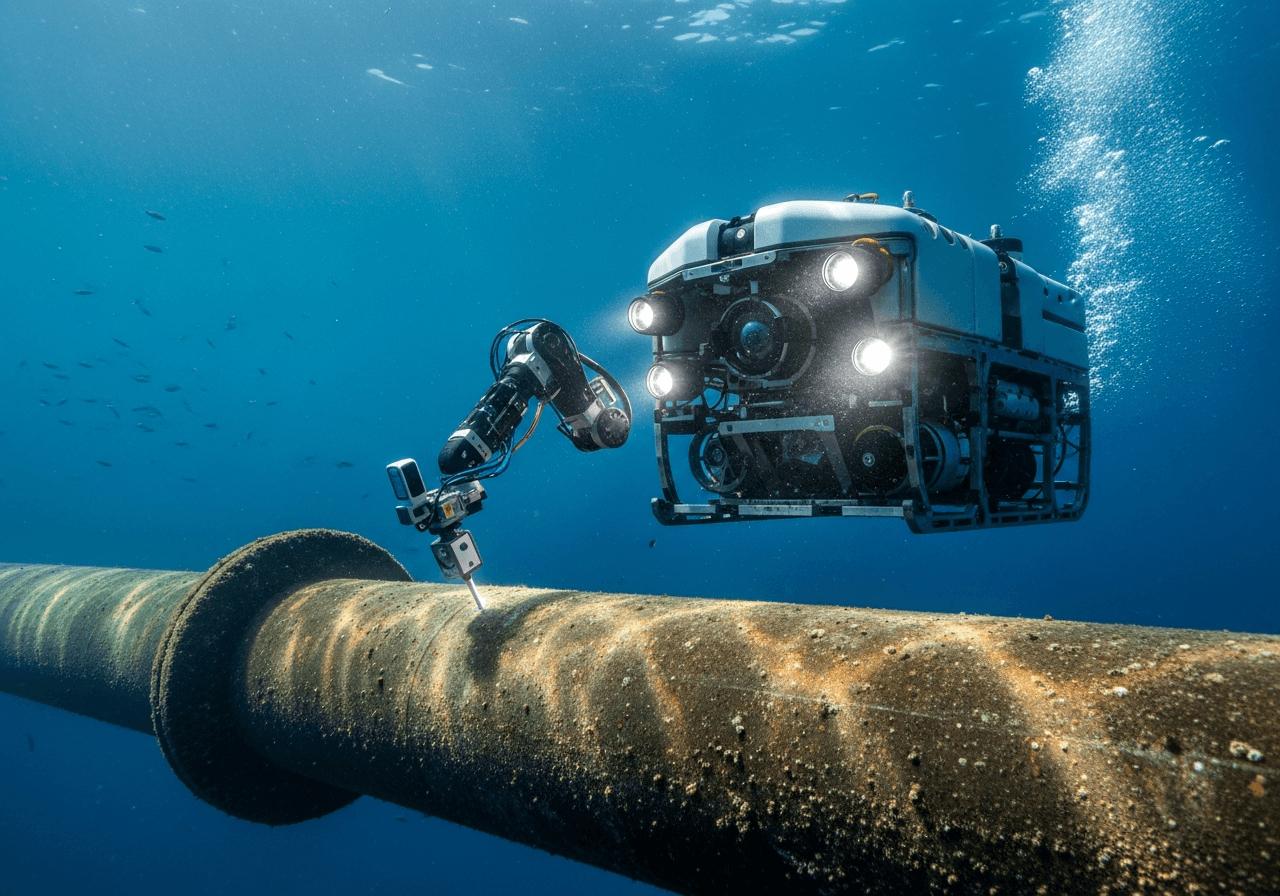
Advanced Technologies for Safe and Efficient Subsea Operations
Keywords:
Subsea Operations, ROV, Subsea Robotics, Offshore Engineering, Underwater TechnologyAbstract
Subsea operations are essential for the development and maintenance of offshore infrastructure, particularly in oil and gas, renewable energy, and marine engineering. However, operations in deepwater environments face various challenges, including high pressure, limited visibility, strong currents, complex seabed conditions, and safety risks. This article aims to examine advanced technologies that support safer and more efficient subsea operations. A literature review method was used to analyze recent developments in remotely operated vehicles (ROVs), autonomous underwater vehicles (AUVs), subsea robotics, inspection and monitoring systems, and digital technologies. The results indicate that these technologies can improve inspection accuracy, operational efficiency, data collection, and worker safety by reducing the need for direct human intervention in hazardous underwater environments. The integration of robotics, sensors, automation, and digital monitoring also provides opportunities for more effective predictive maintenance and real-time decision-making. However, challenges remain in terms of high investment costs, technological complexity, communication limitations, and the need for skilled personnel. Overall, the adoption of advanced subsea technologies can contribute to safer, more reliable, and efficient offshore operations.
References
[1] O. J. Ochulor, O. O. Sofoluwe, A. Ukato, and D. D. Jambol, “Technological innovations and optimized work methods in subsea maintenance and production,” Eng. Sci. Technol. J., 2024, doi: 10.51594/estj.v5i5.1112.
[2] F. Nauert and P. Kampmann, “Inspection and maintenance of industrial infrastructure with autonomous underwater robots,” Front. Robot. AI, vol. 10, no. August, pp. 1–20, 2023, doi: 10.3389/frobt.2023.1240276.
[3] J. F. Waldner and A. Sadhu, “A Systematic Literature Review of Unmanned Underwater Vehicle-based Structural Health Monitoring Technologies,” J. Infrastruct. Intell. Resil., 2024, doi: 10.1016/j.iintel.2024.100112.
[4] O. J. Ochulor, O. O. Sofoluwe, A. Ukato, and D. D. Jambol, “Challenges and strategic solutions in commissioning and start-up of subsea production systems,” Magna Sci. Adv. Res. Rev., 2024, doi: 10.30574/msarr.2024.11.1.0072.
[5] S. Browns, “Scalable Digital Twin Workflows with Subsea Robotics for Offshore Integrity Management,” in Offshore Technology Conference, 2026. doi: 10.4043/37093-ms.
[6] Y. Pétillot, G. Antonelli, G. Casalino, and F. Ferreira, “Underwater Robots: From Remotely Operated Vehicles to Intervention-Autonomous Underwater Vehicles,” IEEE Robot. Autom. Mag., vol. 26, pp. 94–101, 2019, doi: 10.1109/mra.2019.2908063.
[7] M. Ho, S. El-Borgi, D. Patil, and G. Song, “Inspection and monitoring systems subsea pipelines: A review paper,” Struct. Heal. Monit., vol. 19, no. 2, pp. 606–645, 2020, doi: 10.1177/1475921719837718.
[8] M. Fun Sang Cepeda et al., “Exploring Autonomous and Remotely Operated Vehicles in Offshore Structure Inspections,” J. Mar. Sci. Eng., vol. 11, no. 11, 2023, doi: 10.3390/jmse11112172.
[9] O. O. Sofoluwe, O. J. Ochulor, A. Ukato, and D. D. Jambol, “AI-enhanced subsea maintenance for improved safety and efficiency: Exploring strategic approaches,” Int. J. Sci. Res. Arch., 2024, doi: 10.30574/ijsra.2024.12.1.0766.
[10] A. A. Dalhatu, A. Sa’ad, R. Cabral, and G. De Tomi, “REMOTELY OPERATED VEHICLE TAXONOMY AND EMERGING METHODS OF INSPECTION, MAINTENANCE AND REPAIR OPERATIONS: AN OVERVIEW AND OUTLOOK,” J. Offshore Mech. Arct. Eng., 2022, doi: 10.1115/1.4055476.
[11] S. Chen et al., “Design of a Digital Twin System for Deepwater Installation Systems,” Digit. Twins Appl., vol. 3, no. 1, pp. 1–12, 2026, doi: 10.1049/dgt2.70020.
[12] I. C. Sang and W. R. Norris, “An Autonomous Underwater Vehicle Simulation With Fuzzy Sensor Fusion for Pipeline Inspection,” IEEE Sens. J., vol. 23, no. 8, pp. 8941–8951, 2023, doi: 10.1109/JSEN.2023.3250721.
[13] S. Pedersen, J. Liniger, M. Von Benzon, F. F. Sorensen, and C. Mai, “Towards Autonomous Subsea Maintenance on Offshore Structures with Unmanned Underwater Vehicles,” Ocean. Conf. Rec., 2024, doi: 10.1109/OCEANS51537.2024.10682312.
[14] T. Theocharidis and E. Kavallieratou, “Underwater communication technologies: a review,” Telecommun. Syst., vol. 88, no. 2, 2025, doi: 10.1007/s11235-025-01279-x.
[15] B. Weihnacht et al., “Sensor platform for periodic integrity inspection of subsea structures with a permanently installed measuring system,” 11th Eur. Work. Struct. Heal. Monit. EWSHM 2024, pp. 1–8, 2024, doi: 10.58286/29692.
[16] A. G. Rumson, “The application of fully unmanned robotic systems for inspection of subsea pipelines,” Ocean Eng., vol. 235, no. July, 2021, doi: 10.1016/j.oceaneng.2021.109214.